Engineered for high torque density, zero rotational backlash, and extended L10 bearing lifespan. Explore our primary strain wave drives and precision gear units.
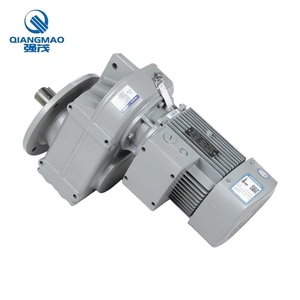
High-load endurance design optimized for continuous textile machinery duty cycles and tight space constraints.
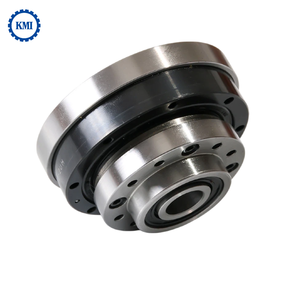
Ultra-thin cup structure offering ultra-low positioning backlash for cobot articulation joints.
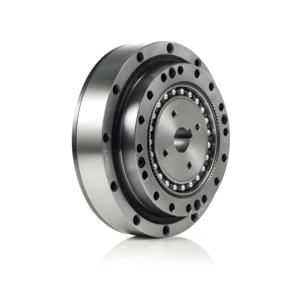
Large hollow bore design allowing internal cabling and pneumatics routing directly through the joint axis.
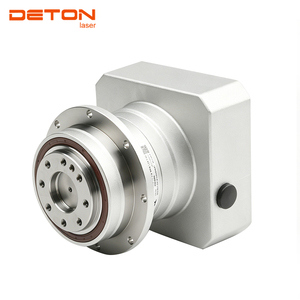
Heavy-duty helical planetary mechanism built for high dynamic acceleration and precision laser head positioning.
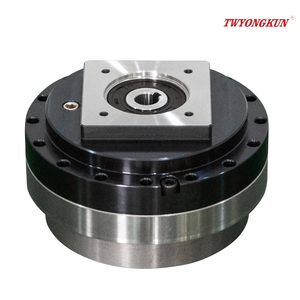
Industrial-grade strain wave speed reducer designed for high repeatability in multi-axis automation lines.
High torsional stiffness unit optimized for seamless flange coupling with major global servo motor brands.
Corrosion-resistant stainless steel housing ideal for washdown food processing and pharmaceutical robotics.
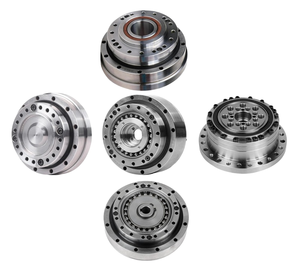
Direct OEM solution with full factory warranty, engineered specifically for solar tracking and medical imaging positioning.
Understanding Information Gain in Motion Control: Elastic Deformation Mechanics, Metallurgy Innovation, and Zero-Backlash Transmission Efficiency.
Harmonic reducers (strain wave drives) represent the pinnacle of mechanical reduction technology. Unlike conventional spur, helical, or planetary gearboxes that rely on rigid tooth contact across multiple moving parts, a harmonic drive utilizes controlled elastic deformation to achieve ultra-high torque transmission ratio within an incredibly compact footprint.
Comprising three essential components—the Wave Generator (an elliptical ball-bearing assembly), the Flexspline (an ultra-thin flexible steel cup with external teeth), and the Circular Spline (a rigid internal ring with internal teeth)—the system transmits motion via wave propagation. As the elliptical wave generator rotates inside the flexspline, it causes the flexspline's teeth to engage smoothly with the circular spline at opposite ends of the major axis.
Because the flexspline has two fewer teeth than the circular spline, each 360° rotation of the wave generator drives the flexspline backward by exactly two teeth relative to the circular spline. This mechanism achieves gear ratios from 30:1 up to 160:1 in a single stage with zero rotational play.
As global automation transitions towards humanoid robotics, high-speed intralogistics, and green energy manufacturing, precision strain wave gearing sourcing is experiencing four major structural shifts.

Modern collaborative robots (cobots) and emerging humanoid robotics require ultra-lightweight joint modules. Buyers are shifting from standalone speed reducers to fully integrated frameless joint actuators—combining a hollow-shaft harmonic drive, frameless BLDC motor, dual absolute encoders, and torque sensors in one compact housing.

Factory automation designs demand higher power-to-weight ratios. Industrial buyers now specify strain wave reducers capable of delivering 20% to 40% higher torque output at frame sizes under 14 (outer diameter < 50mm) to allow smaller machine footprints without sacrificing dynamic payload capability.

With massive expansion in solar photovoltaic manufacturing, semiconductor lithography, and aerospace optical gimbals, procurement teams are requesting specialized gear surface nitriding and synthetic fluorine lubricants capable of operating in high vacuum (10^-5 Pa) and extreme thermal ranges (-40°C to +150°C).
From automotive assembly robot arms to cleanroom pharmaceutical packing lines, our strain wave gearboxes are validated against continuous duty cycle stresses.
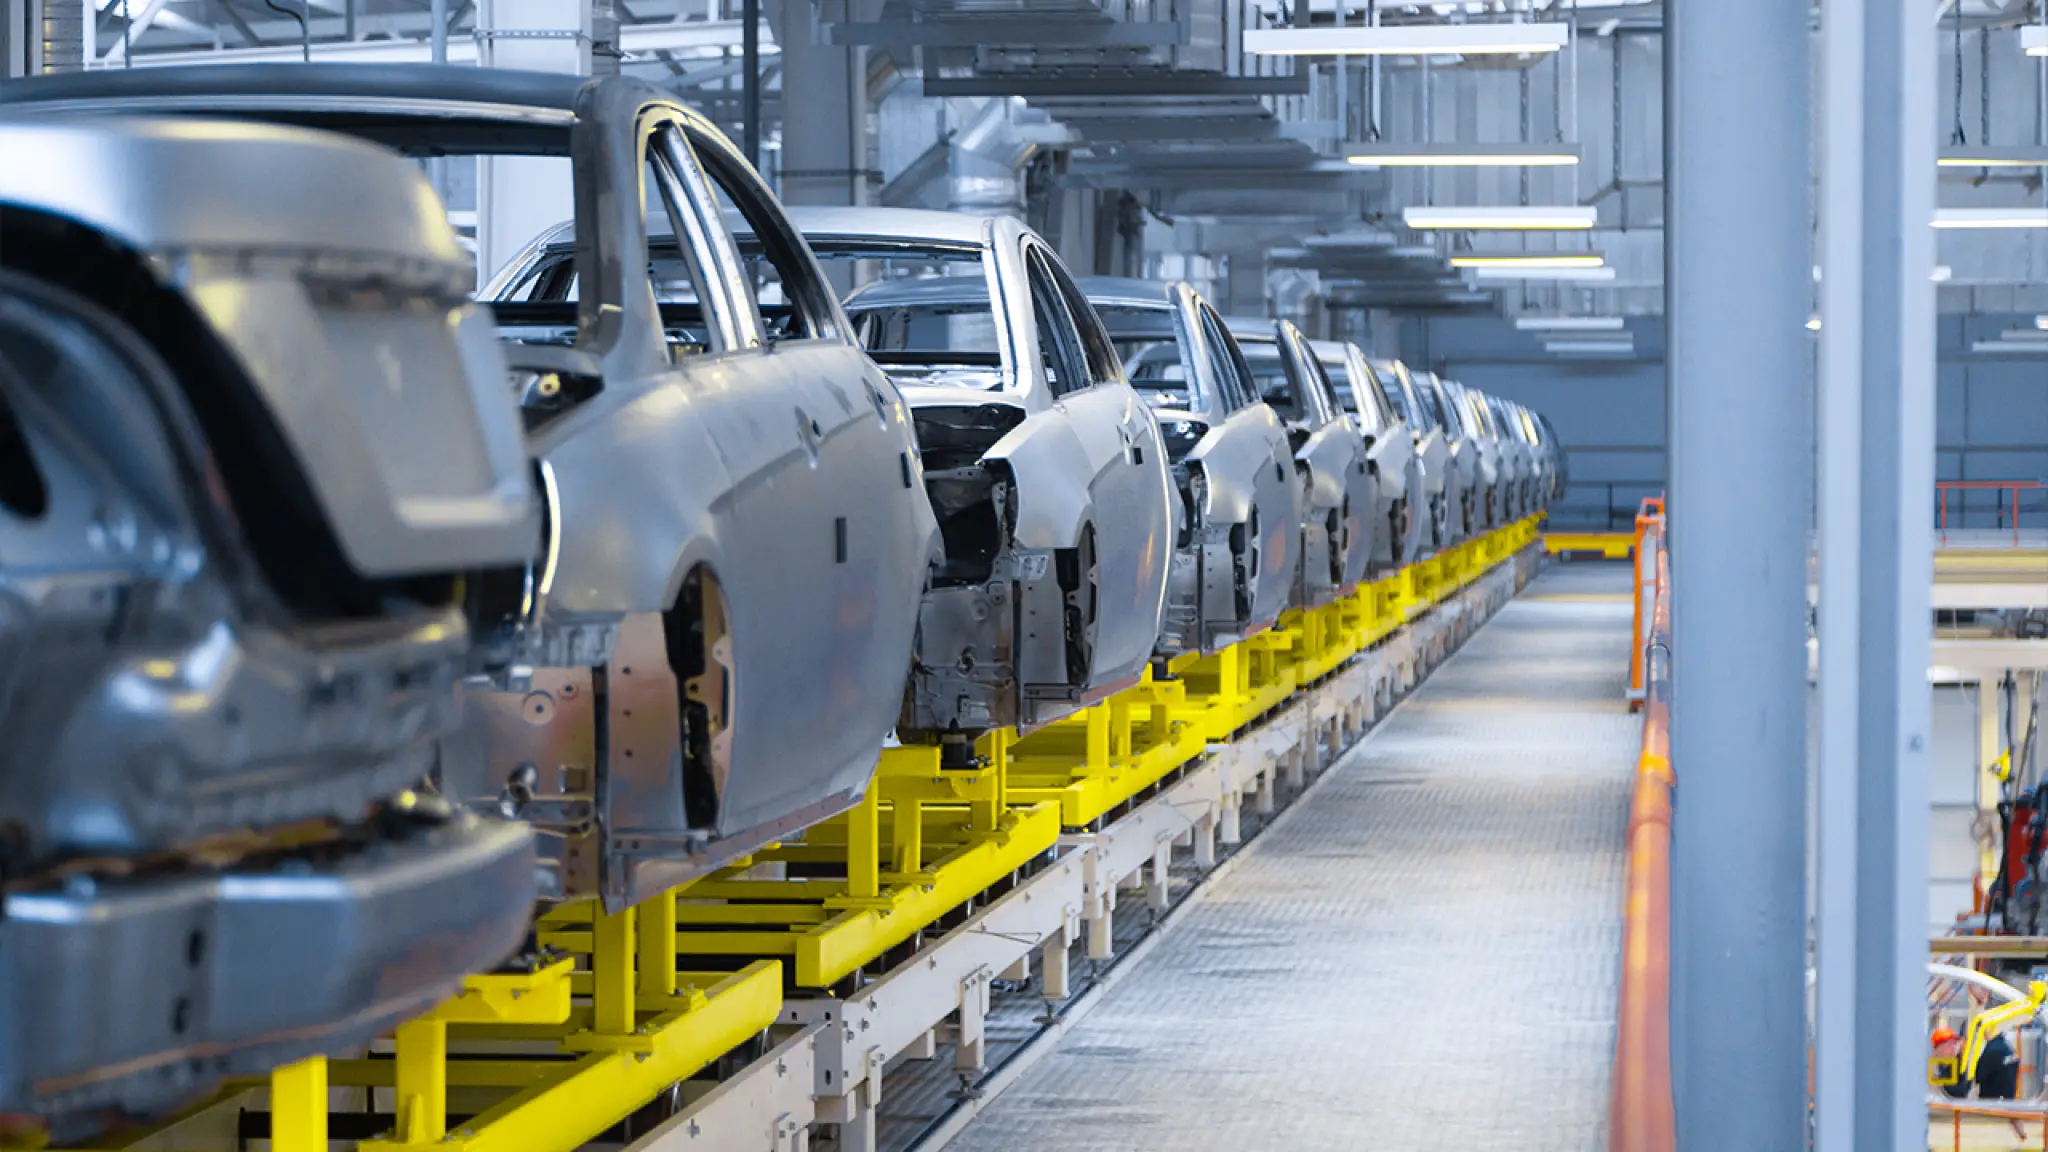
High dynamic accuracy is paramount in robotic spot welding, screwdriving, and battery module pick-and-place lines. Zero backlash prevents micro-vibrations during high-speed path motion, ensuring sub-millimeter weld positioning and eliminating product rework costs.
Automated Guided Vehicles (AGVs) and Autonomous Mobile Robots (AMRs) demand compact, high-efficiency wheel reduction gears and steering joint drives that maximize battery lifecycle while absorbing shock loads during uneven floor transitions.
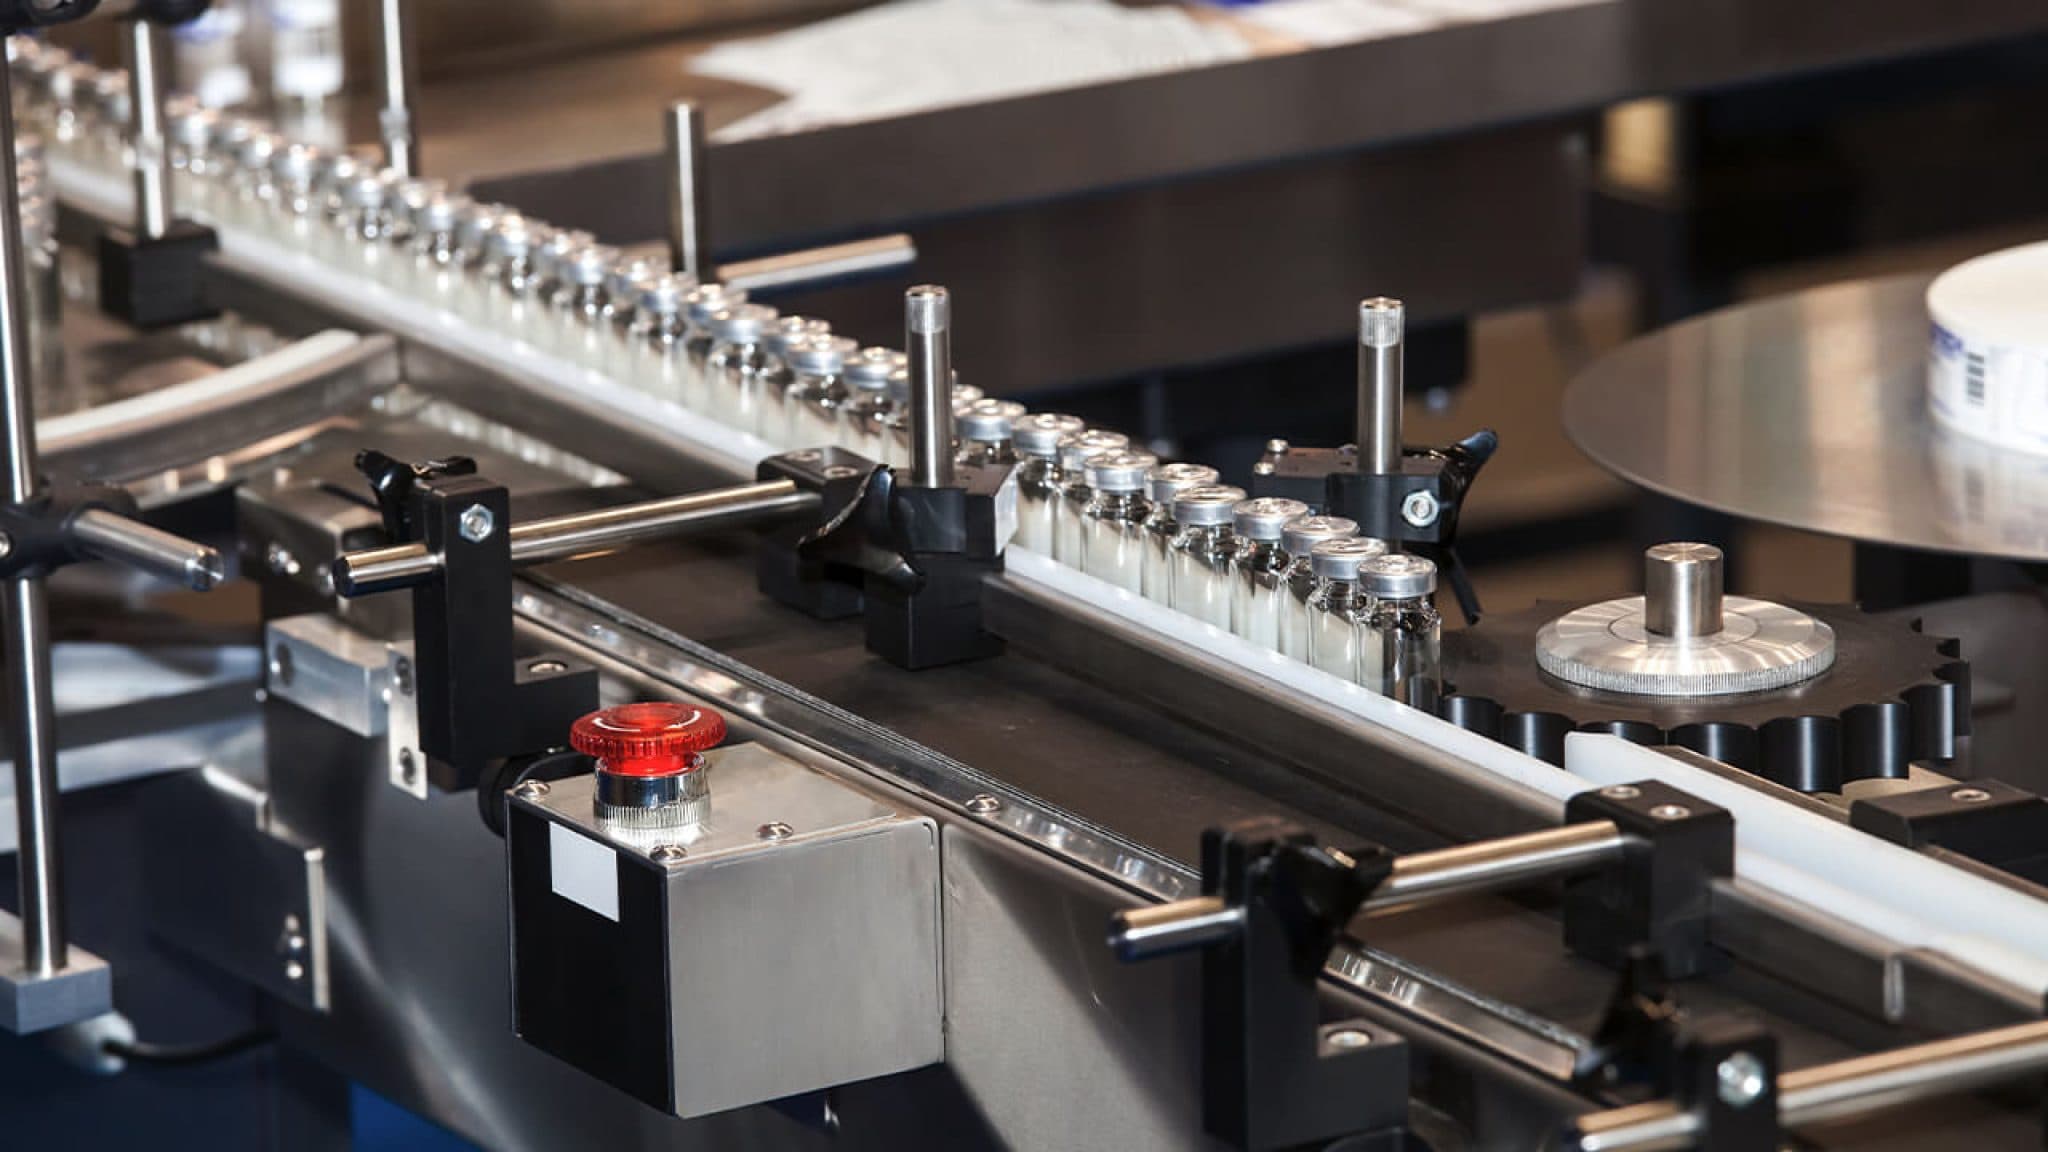
In sterile bottling, blister packaging, and automated vision inspection cells, stainless-steel strain wave reducers deliver cleanroom-compliant, zero-gassing motion control capable of handling high-frequency indexing without lubricant leakage.
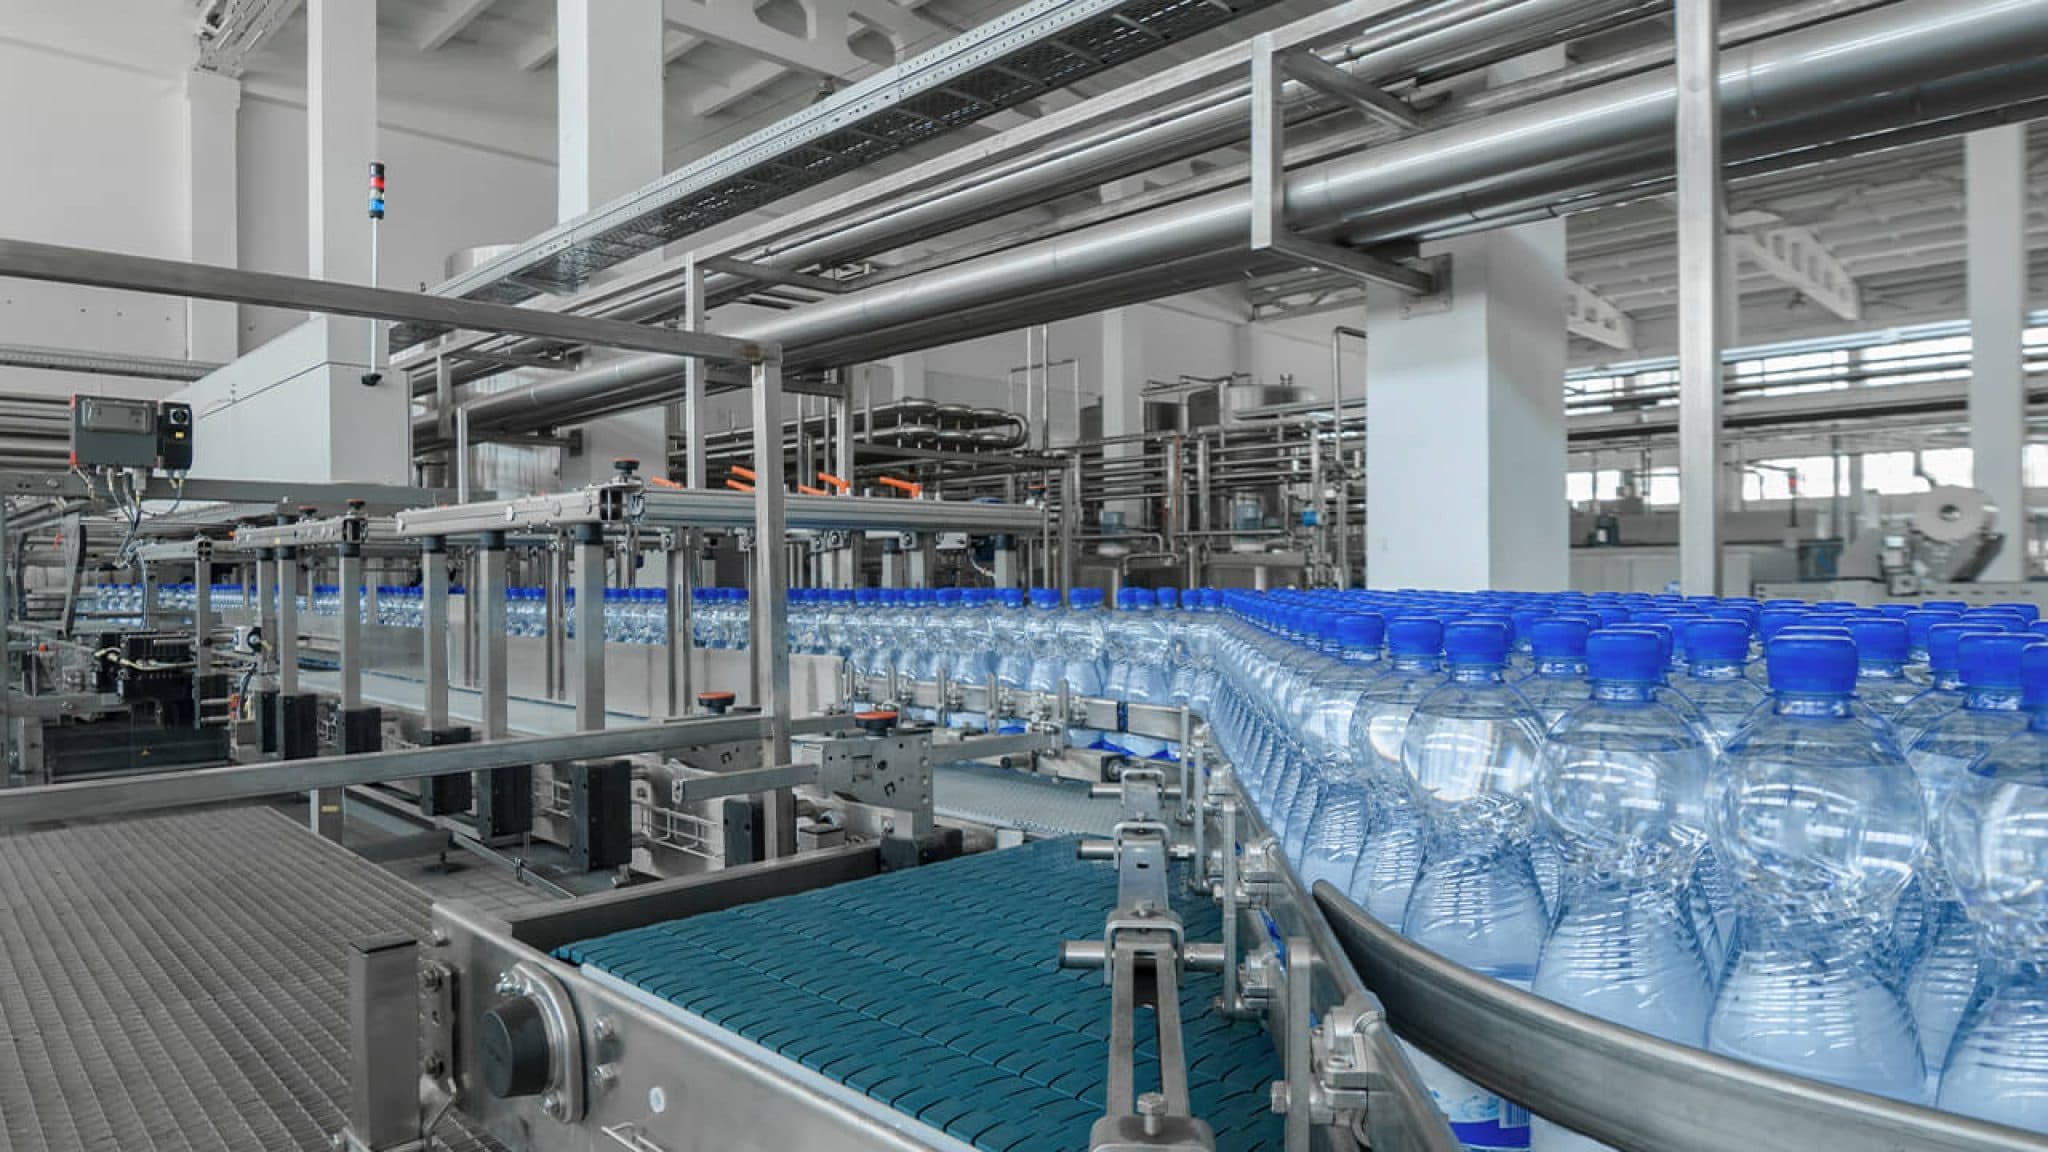
Side-entry robotic demolding demands instantaneous acceleration and deceleration. High torsional rigidity strain wave gearboxes resist elastic twisting under rapid inertia changes, cutting shot cycle times significantly.
Combining 25+ years of factory-floor automation experience with ISO 9001 quality management, complete traceability, and international compliance testing.
Unlike assemble-only trading entities, our partner manufacturing plants maintain total process control—from raw gear blank forging to final dynamic hysteresis testing.
Every flexspline tooth geometry and circular spline pitch is measured on German ZEISS 3D coordinate measuring machines to ensure DIN 3962 Grade 4 tooth profile accuracy.
Each dispatched speed reducer undergoes automated torsional stiffness testing to record exact lost motion, transmission accuracy (<45 arcsec), and starting torque curves.
Assembly is completed within ISO Class 7 cleanrooms using high-vacuum degassed grease to prevent air-bubble encapsulation and guarantee 15,000+ hours L10 service life.
Choosing the correct reduction technology for your multi-axis robotics system is critical to balancing torque density, backlash limits, and total capital cost.
| Performance Parameter | Harmonic Reducer (Strain Wave) | High-Precision Planetary Reducer | RV Vector Reducer |
|---|---|---|---|
| Rotational Backlash | Zero Backlash (< 10 arcsec) | 1 to 3 arcmin | < 1 arcmin |
| Single-Stage Ratio Range | 50:1 to 160:1 | 3:1 to 10:1 | 30:1 to 200:1 |
| Torque Density / Weight Ratio | Extremely High (Compact) | Moderate | High (Heavy Duty) |
| Structural Form Factor | Flat Cup / Pancake / Hollow Shaft | Inline Cylindrical | Large Diameter Disc |
| Optimal Robotics Application | Robot Arm Joints 4, 5, 6 & Cobots | Gantry Axis & Linear Tracks | Robot Base Joints 1, 2, 3 & Heavy Positioners |
| Shock Load Loadability | Medium (Requires S-Tooth Protection) | High | Extremely High |
Direct technical answers addressing gear selection, custom OEM shaft modifications, testing reports, and international shipping logistics.
Our speed reducers feature modular motor adapter flanges and flexible input couplings engineered to connect directly with major industrial automation motor standards.
Get in touch with our senior application engineers to download 2D/3D CAD models, request custom shaft dimensions, or receive a competitive factory-direct quote within 24 hours.